Robot learning · World models · VLAs · Perception · Action segmentation · Manipulation
Shahram Najam Syed
I make robots (and the models inside them) go brrrr.
Robot learning should inherit its architecture from biological sensorimotor control. Nervous systems never wait for a world that holds still. They meet uncertainty with one unbroken cascade from perception to memory, and that cascade is what lets a body act in places it has never been. I want robots to learn the same way, closing the loop between language, vision and action so that every action becomes something they understand.
- 01 Segment
The brain binds the senses and carves continuous experience into discrete events. Multimodal temporal representations align video in time, segment long-horizon procedures with little or no supervision, and let touch stand in when vision drops out.
Aligning Videos in Time · Visuo-Acoustic Hand Pose · THING (in progress)
- 02 Predict
The cerebellum forecasts the sensory consequences of every motor command. Latent world models roll a policy's future forward before it acts, and a few probing motions identify the dynamics of an unfamiliar object before the first real attempt.
- 03 Correct
Prediction error drives behavior. Imagined rollouts are checked against the manifold of demonstrated behavior, so drift is caught and recovered from before it happens physically.
FAR · Ariadne's Clew (in progress)
- 04 Consolidate
The brain replays experience and strengthens only the connections that matter. Vision-language-action policies adapt online through experience replay and parameter-efficient fine-tuning of the layers that count, which sharpens what the next cycle perceives.
ExpReS-VLA · Not All Layers Need Tuning · Hierarchical Skill Retrieval
Technical Lead, Applied Research at Stealth, and Visiting Scholar at the Carnegie Mellon Robotics Institute.
- ICRA 2026 Best Paper finalist
- CMU Robotics Institute Outstanding Graduate Research Assistant Award and Best Robotics Technology Student, 2025
- CVPR, ICRA, CoRL, RSS, IROS, ISMAR and a granted US patent
Publications and patents
Work in progress
- 2027THING: Translating Haptics Into Native-Token Grasping
S.N. Syed, A. Jakobsson, P. Sachdev, J. Ichnowski
In preparation for Robotics: Science and Systems (RSS 2027)
- 2027Preview coming soonAriadne's Clew: Predictive Temporal Alignment of Imagined Rollouts to Human Demonstrations
S.N. Syed, A. Jakobsson, P. Sachdev, J. Ichnowski
In preparation for the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2027)
Under review
- 2027Not All Layers Need Tuning: Diagnosing and Directing Adaptation in Vision-Language-Action Models
S.N. Syed, A. Jakobsson, P. Sachdev, J. Ichnowski
Submitted to the IEEE International Conference on Robotics and Automation (ICRA 2027)
- 2026Hierarchical Skill Retrieval for Data-Efficient Adaptation of Vision-Language-Action Models
H. Hao, S.N. Syed, J. Schneider, J. Ichnowski
Under review at IEEE Robotics and Automation Letters (RA-L)
Conferences
- 2026Intercepting the Future: Latent-Space Predictive World Model for Dynamic VLA Manipulation
S.N. Syed, A. Jakobsson, H. Hao, J. Ichnowski
Conference on Robot Learning (CoRL 2026)
- 2026FAR: Failure-Aware Retry for Test-Time Recovery and Continual Policy Improvement
H. Hao, S.N. Syed, J. Ichnowski, J. Schneider
Conference on Robot Learning (CoRL 2026)
- 2026Wiggle and Go! System Identification for Zero-Shot Dynamic Rope Manipulation
A. Jakobsson, A. Mahajan, K. Pullalarevu, K. Suresh, Y. Mao, B.P. Duisterhof, Y. Yao, S.N. Syed, J. Ichnowski
Conference on Robot Learning (CoRL 2026)
- 2026
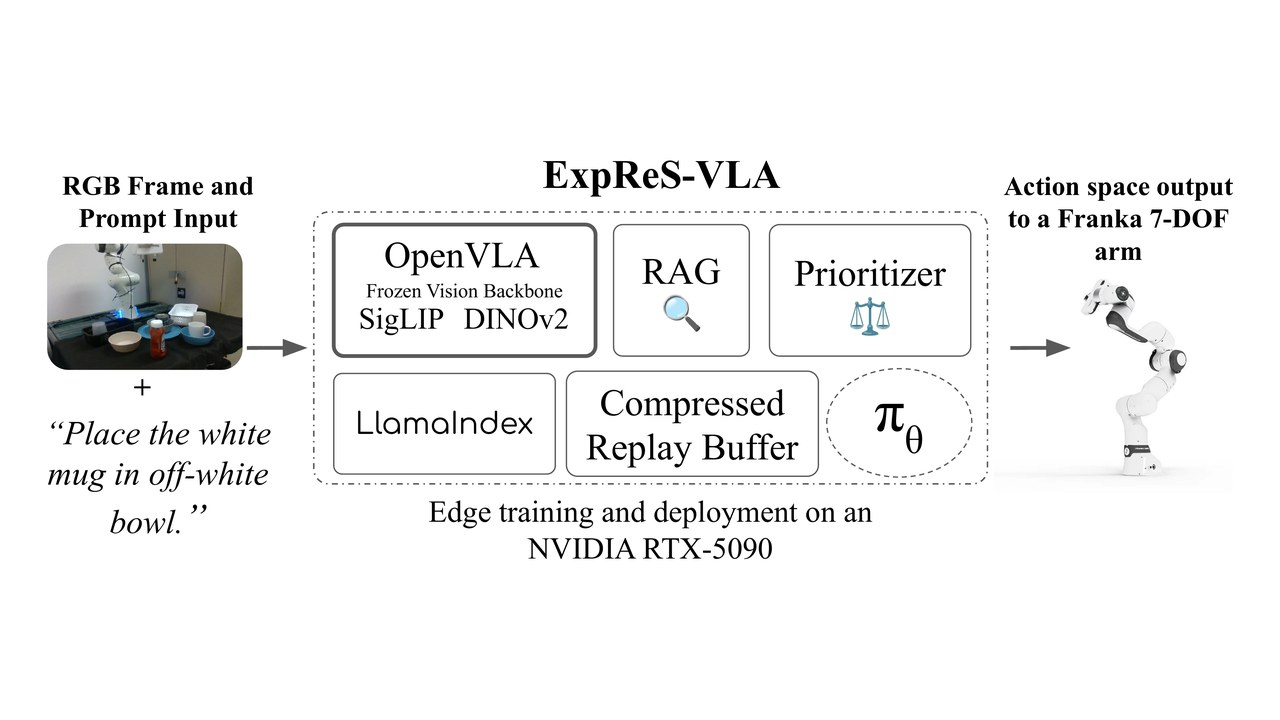 ExpReS-VLA: Specializing Vision-Language-Action Models Through Experience Replay and Retrieval
S.N. Syed, Y. Ahuja, A. Jakobsson, J. Ichnowski
IEEE International Conference on Robotics and Automation (ICRA 2026) Best Paper finalist
- 2021Learning by Aligning Videos in Time
S. Haresh, S. Kumar, H. Coskun, S.N. Syed, A. Konin, M.Z. Zia, Q.H. Tran
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR 2021)
- 2020RetroActivity: Rapidly Deployable Live Task Guidance Experiences
A. Konin, S.N. Syed, S. Siddiqui, S. Kumar, Q.H. Tran, M.Z. Zia
IEEE International Symposium on Mixed and Augmented Reality (ISMAR 2020), demonstration Best Demo Award
- 2020
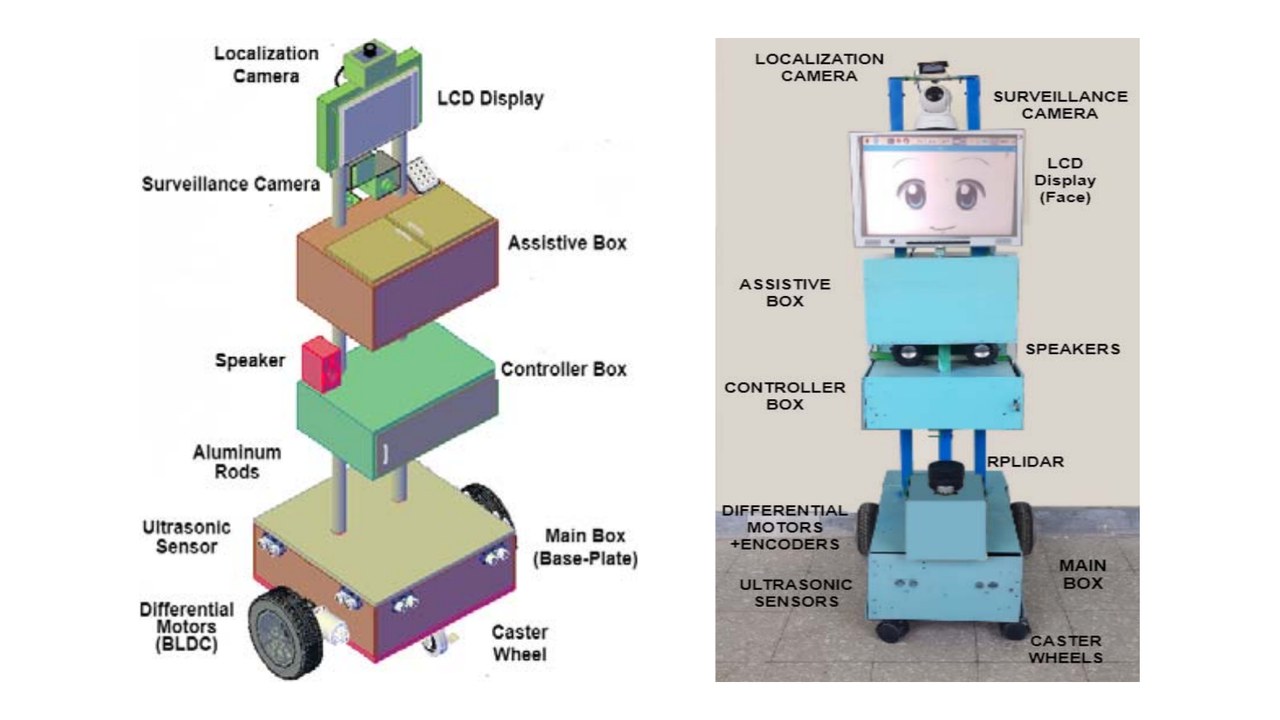 Assistive Mobile Robot for Industrial and Academic Applications
S.R.N. Jafri, A. Ahmed, A. Azam, U.B. Ihsan, S.N. Syed, R. Uddin
International Bhurban Conference on Applied Sciences and Technology (IBCAST 2020)
- 2016ICONICS2016Greenhouse Monitoring and Automation System
S.N. Syed, A.Z. Shaikh
International Conference on Innovations in Computer Science and Software Engineering (ICONICS 2016)
Journals
- 2018Mehran University Research Journal2018A Novel Hybrid Biometric Electronic Voting System: Integrating Fingerprint and Face Recognition
S.N. Syed, A.Z. Shaikh, S. Naqvi
Mehran University Research Journal of Engineering and Technology, 37(1)
- 2017IJAAS2017Remote Monitoring System for Diesel Generators at Cellular Base Stations
S.N. Syed, A.Z. Shaikh, S. Naqvi, T. Altaf
International Journal of Advanced and Applied Sciences, 4(8)
Patents
- 2025Bump Detection for Facilitating a Defined Vehicle Stop Behavior
J. Shah, S. Jha, D.R. Pamnani, A. Pulapaka, P. Oza, T. Eto, T. Aguiar, L. Pedersen, Z. Guter, P.N. Shah, S.S. Undavalli, S. Muthusamy, S.N. Syed
US patent application with Nissan North America, Inc. · Docket NNA2-5544-A · Filed July 2025 Pending
- 2025Automated Mapping for Localization in a Controlled Environment
S. Jha, P. Oza, L. Pedersen, A. Pulapaka, D.R. Pamnani, J. Shah, T. Eto, Z. Guter, P.N. Shah, S.S. Undavalli, S.N. Syed, S. Muthusamy
US patent application with Nissan North America, Inc. · Docket NNA2-5546-A · Filed July 2025 Pending
- 2025Autonomous Navigation in Controlled Environments
S. Jha, P. Oza, L. Pedersen, A. Pulapaka, D.R. Pamnani, J. Shah, Z. Guter, P.N. Shah, S.S. Undavalli, S.N. Syed, S. Muthusamy
US patent application with Nissan North America, Inc. · Docket NNA2-5547-A · Filed July 2025 Pending
- 2022System and Method for Correlating Video Frames in a Computing Environment
Q.H. Tran, M.Z. Zia, A. Konin, S. Haresh, S. Kumar, S.N. Syed
US Patent 11,368,756 Granted
Preprints
- 2026
- 2025
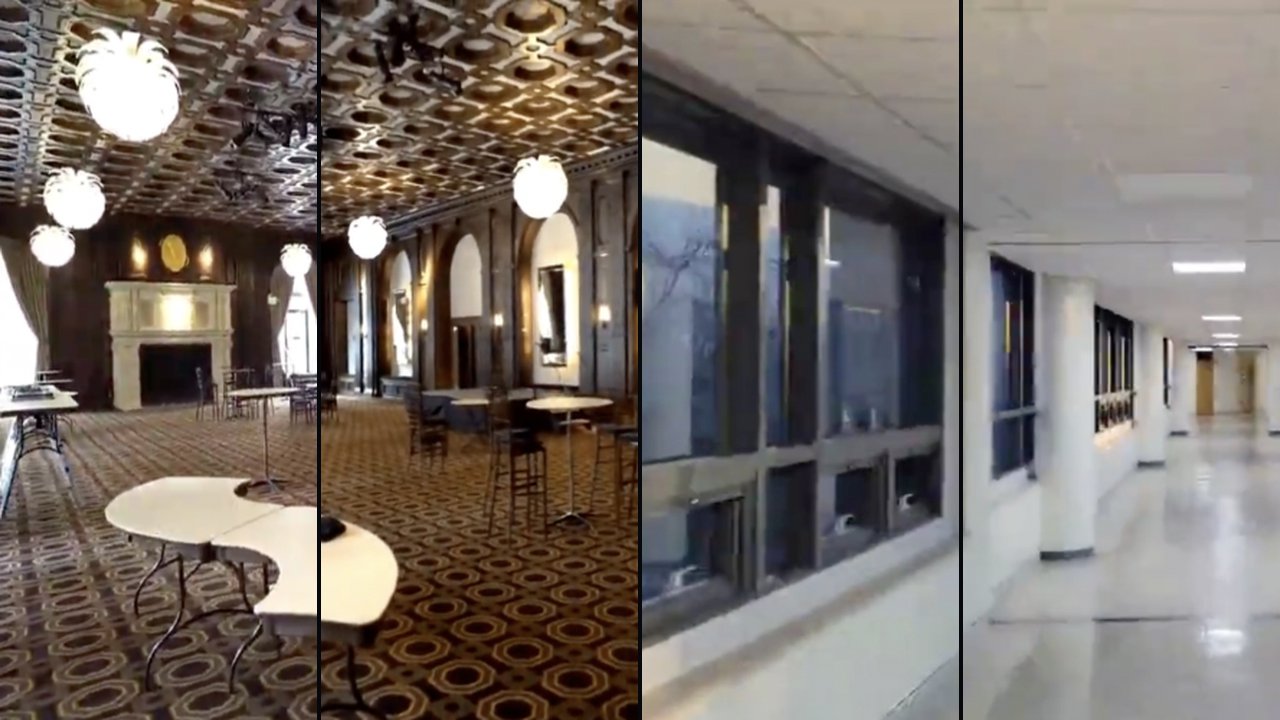 Joint Learning of Depth, Pose, and Local Radiance Field for Large Scale Monocular 3D Reconstruction
S.N. Syed, Y. Hu, Y. Yao
arXiv preprint arXiv:2512.18237
- 2025Visuo-Acoustic Hand Pose and Contact Estimation
Y. Mao, U. Yoo, Y. Yao, S.N. Syed, L. Bondi, J. Francis, J. Oh, J. Ichnowski
arXiv preprint arXiv:2508.00852
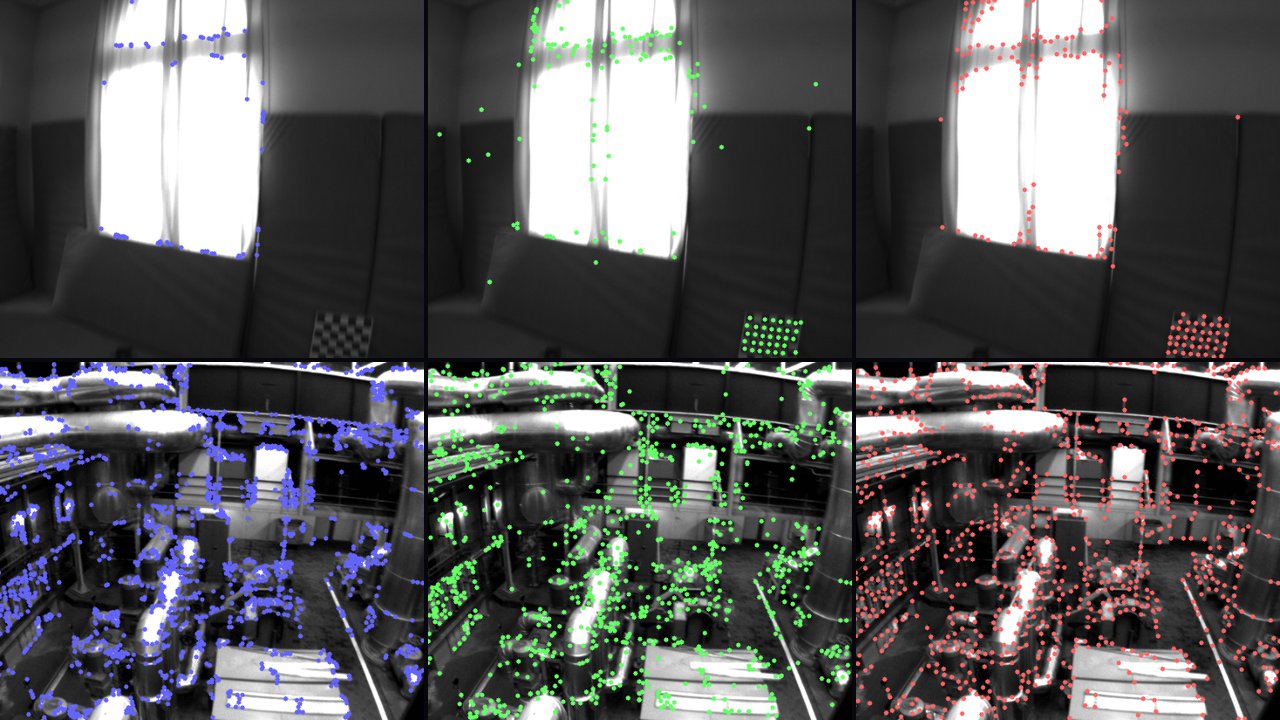
- 2025Preview coming soonSuperPoint-SLAM3: Augmenting ORB-SLAM3 with Deep Features, Adaptive NMS, and Learning-Based Loop Closure
S.N. Syed, I. Roongta, K. Ravie, G. Nageswar
arXiv preprint arXiv:2506.13089
Experience
- Jun 2025 – nowStealth
Technical Lead, Applied Research
- Jun 2025 – now

Visiting Scholar, Momentum Lab
- Jun 2024 – Aug 2024
Research Intern, Perception and Autonomy
- Aug 2023 – Apr 2025
Research Assistant
- Jun 2022 – Jul 2023
Senior Robotics Engineer (Contractor)
- Jul 2019 – May 2021
Contractor (SBIR)
- Nov 2018 – Jul 2023
 Retrocausal
Founding Engineer and Lead Research Engineer
Education
- 2023 – 2025
M.S. Robotic Systems Development · GPA 4.00
Outstanding Graduate Research Assistant Award and Best Robotics Technology Student, Class of 2025.
- 2014 – 2018
 NED University of Engineering and Technology
B.E. Electronic Engineering, with distinction
Ranked 9th of 143. Undergraduate researcher in the Autonomous Systems Lab.
News
- Nov 2026Talk
Invited talk at Harvard Medical School, hosted by Pierre Dupont, on world action models and their use in model predictive control for cardiac surgery.
- Oct 2026Award
Named an Outstanding Reviewer at CoRL 2026.
- Sep 2026Paper
Not All Layers Need Tuning submitted to ICRA 2027.
- Sep 2026Paper
Three papers accepted to CoRL 2026: Intercepting the Future, FAR and Wiggle and Go!.
- Aug 2026Recognition
Awarded a Certificate of Appreciation by the Executive Office of the President, White House Office of Science and Technology Policy, for serving as an expert judge in the first Presidential AI Challenge.
- Aug 2026Paper
Hierarchical Skill Retrieval under review at IEEE Robotics and Automation Letters.
- Jul 2026Award
Best Reviewer Award at the ICML 2026 Second Workshop on Agents in the Wild (AIWILD).
- Jun 2026Service
Expert judge for the first Presidential AI Challenge at the state, regional and national levels, with the national round at the White House.
Earlier news
- Jan 2026Paper
ExpReS-VLA accepted to ICRA 2026, later named a Best Paper finalist.
- Nov 2025Award
Outstanding Graduate Research Assistant Award and Outstanding Graduate Teaching Assistant Award (Honorable Mention), CMU Robotics Institute, 2025.
- Jun 2025Career
Joined Stealth as Technical Lead, Applied Research, and the CMU Momentum Lab as a Visiting Scholar.
- Apr 2025Award
Best Robotics Technology Student Award, CMU Robotics Institute, Class of 2025.
- Jun 2024Career
Started as an autonomy and perception intern at Nissan North America.
- Aug 2023Career
Started the M.S. in Robotic Systems Development at the Robotics Institute, Carnegie Mellon University.
- Jul 2022Recognition
Retrocausal named to the CB Insights Advanced Manufacturing 50, the top 50 of more than 6,000 advanced manufacturing startups.
- Jun 2022Patent
Granted US Patent 11,368,756, System and Method for Correlating Video Frames in a Computing Environment.
- May 2021Award
Retrocausal won the Judges' Award at the 2021 Vision Tank start-up competition.
- Mar 2021Paper
Learning by Aligning Videos in Time accepted to CVPR 2021.
- Nov 2020Award
ISMAR 2020 Best Demo Award for RetroActivity: Rapidly Deployable Live Task Guidance Experiences.
- Aug 2020Grant
Funded by a NASA JPL SBIR grant to build a few-shot learning computational model with the Exploration Medical Capability (ExMC) laboratories for crewed Mars missions.
- Nov 2018Career
Joined Retrocausal AI as a Founding Engineer.
Contact
The fastest way to reach me is email.